Your Software Module enabling Space-Efficient, Autonomous Packing
Easy and Space-Efficient Autonomous Packing
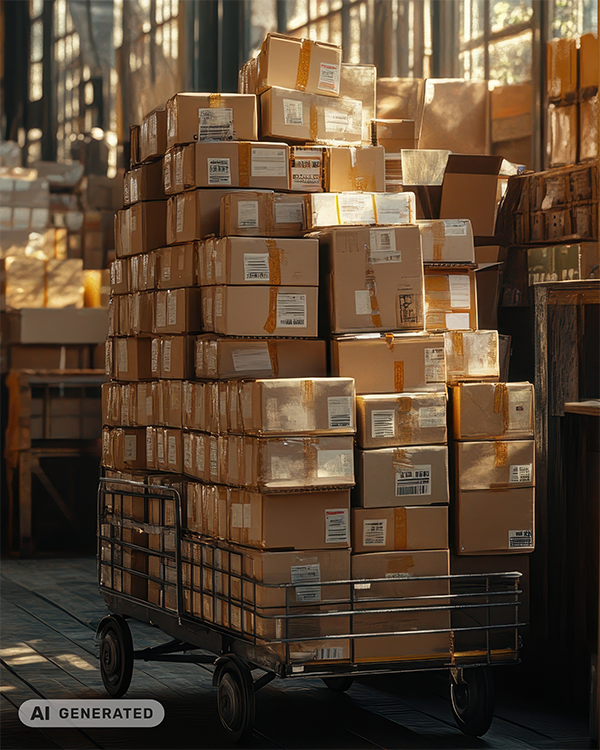
The rc_reason Pack software module provides an out-of-the-box perception solution for autonomous packing. It enables robotic pick-and-place applications that need to place previously picked objects inside a packing volume, such as a box, bin or onto a pallet.
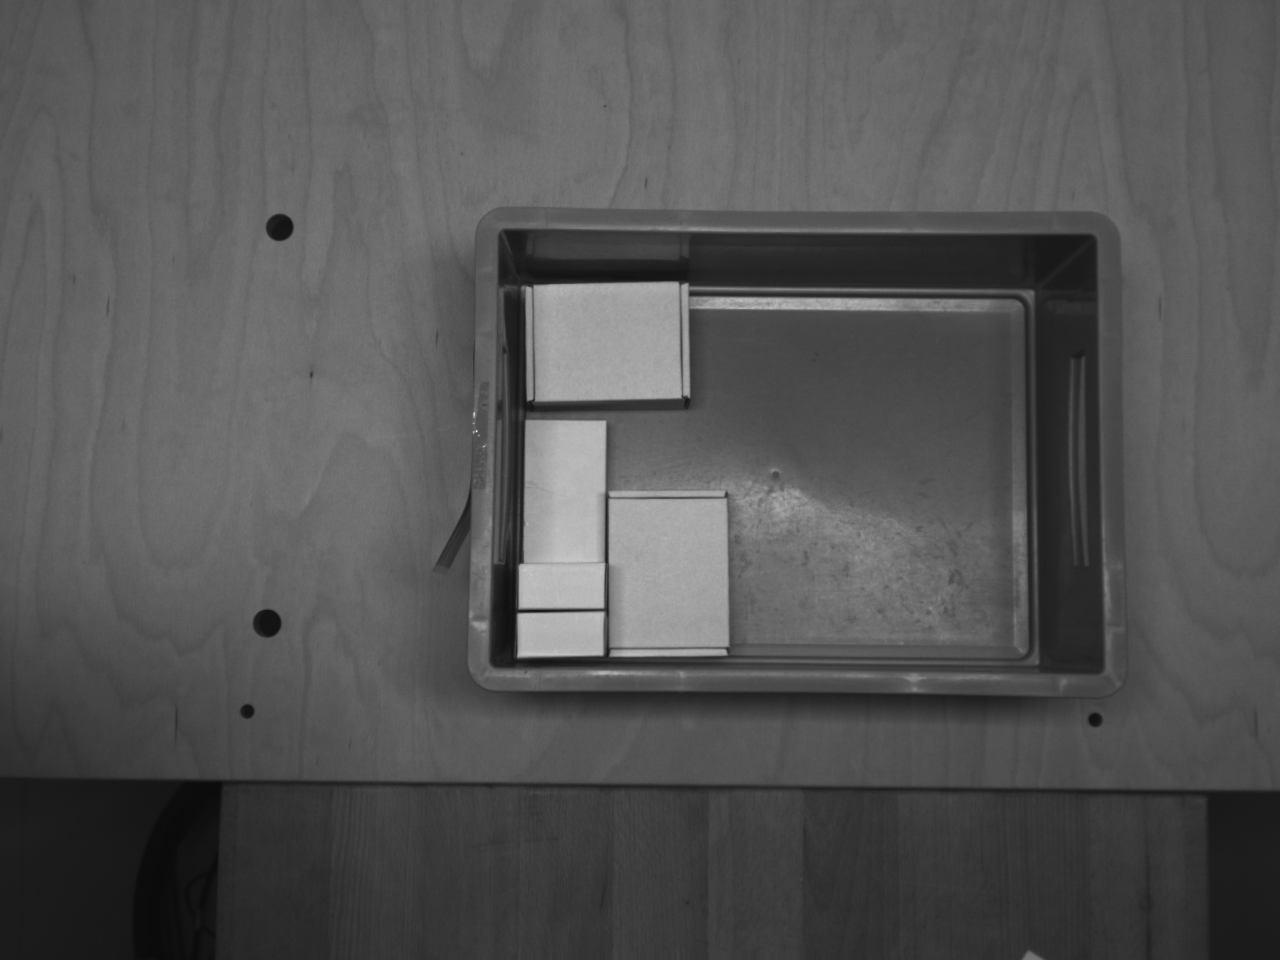
It enables the identification of placement poses for objects inside a packing volume. The software analyzes the current filling state of the packing volume and selects the lowest placement position that provides stable support for the object. Thus, the remaining space is maximized, and as many packing options as possible remain available for the next object to be placed.
Definition of a region of interest for packing volume or load carrier detection
Determines the optimal placement pose based on package dimensions and available packing volume
Works with static and robot-mounted sensors
Out-of-the-box: Easy installation and operation
Details about the Pack Autonomous Packing Software
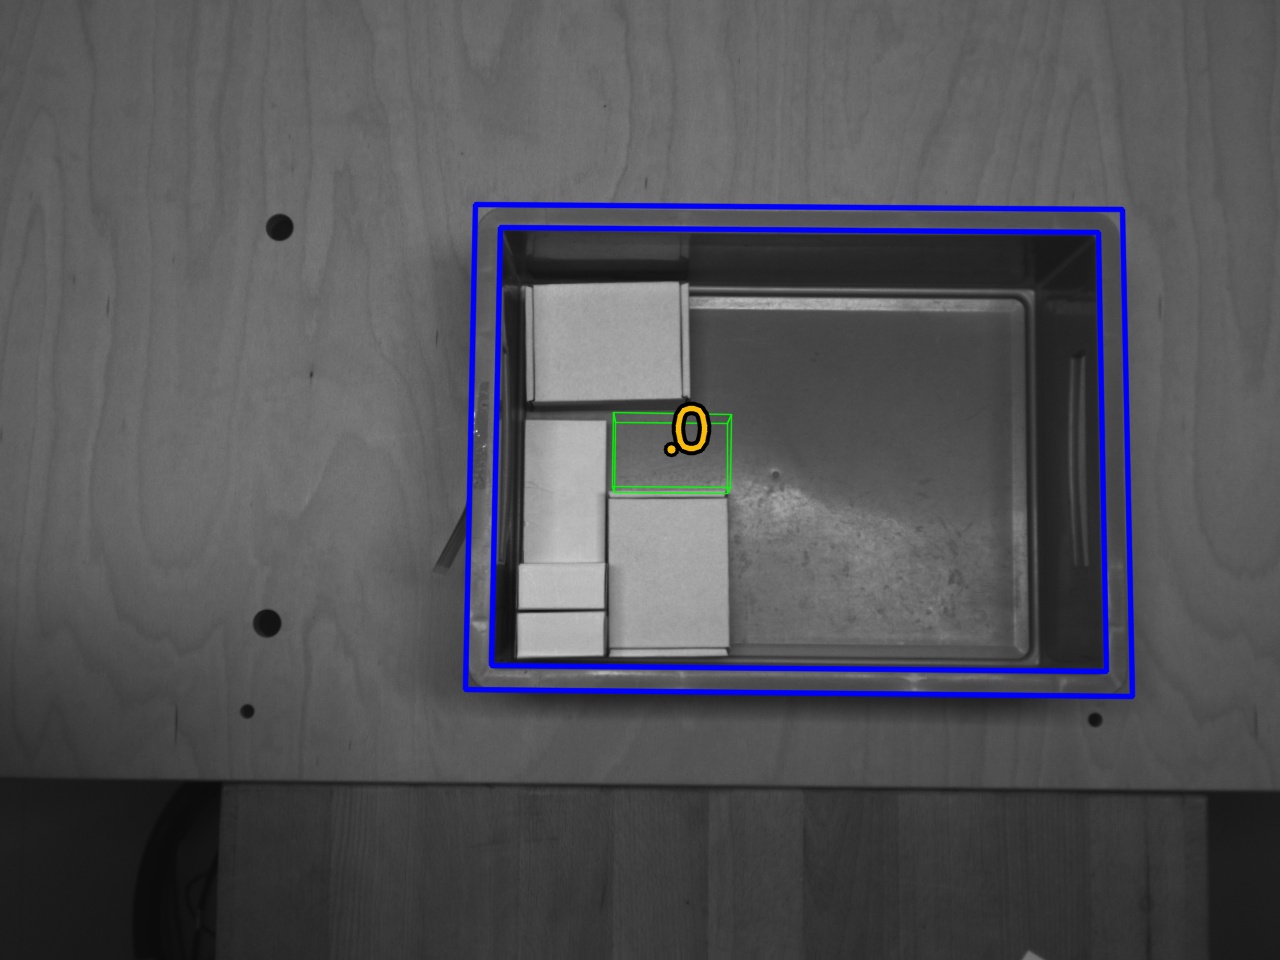
Given the bounding box of the object to be placed and the grasp(s) that can be used to pick it up, Pack computes a pose at which the object can be placed, taking the current filling state of the packing volume into account. The place pose is chosen to be the lowest position that provides stable support for the object, thereby maximizing the residual space left after placing.
In addition, the module offers:
A dedicated page on the rc_cubeWeb GUI for easy setup, configuration, testing, and application tuning.
The definition of a region of interest to specify the relevant packing volume in the scene, or to restrict the search area for the load carrier.
A load carrier detection functionality to place objects inside a detected load carrier only.
A configurable starting point to control where packing begins.
Support for static and robot-mounted cameras and optional integration with the Hand-eye calibration module, to provide place poses in the user-configured external reference frame.
3D visualization of the packing volume and the computed place pose in the Web GUI.
Additional Information for the Pack Autonomous Packing Software
You would like to find out whether our portfolio is suitable for your robotic application? Simply request a feasibility study free of charge, and get a live demo of our products.
Would you like to try out one of our sensors and software solutions? Our Try-&-Buy-option gives you the chance to test our products before you decide, and to be sure you make the right choice for your application.